Stanford and Caltech researchers run humanoid robot on GPT-6 Astra to tidy unfamiliar kitchen
A humanoid robot powered by GPT-6 Astra independently tidied an unfamiliar kitchen using the HomeBody system, which lets the language model call modular skills like grasping and navigating without a specially trained control layer.
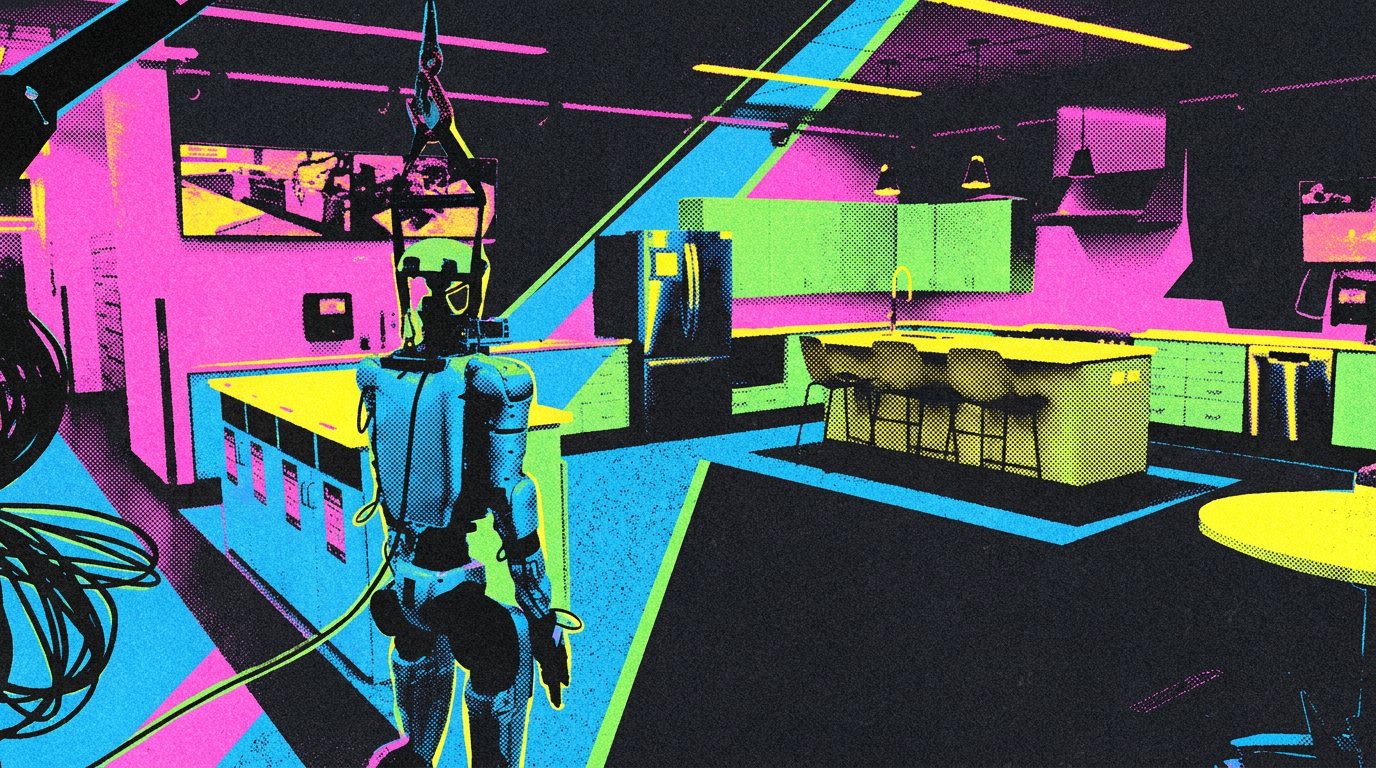
Researchers at Stanford and Caltech have demonstrated a humanoid robot that can independently tidy up an unfamiliar kitchen, with the machine's actions directed by the GPT-6 Astra language model. The experiment, conducted through a system called HomeBody, bypasses the conventional approach of building a specially trained control layer between the artificial intelligence and the robot's physical hardware.
Instead of relying on a separate, task-specific controller, HomeBody allows the language model to call directly into modular skills such as grasping objects and navigating a room. This architecture marks a departure from many existing robotics pipelines, where a language model might interpret a command but then hand off execution to a purpose-built control system trained on the specific environment or task.
The significance of the demonstration lies in the robot's ability to operate in a space it had not previously encountered. Tidying an unfamiliar kitchen requires the system to identify objects, understand their likely places, plan a sequence of movements, and adapt to a layout it has not memorized. By letting GPT-6 Astra invoke modular skills directly, the researchers tested whether a general-purpose language model can orchestrate physical work without a bespoke control layer tailored to the setting.
The HomeBody system's design suggests a broader shift in robotics research, where the intelligence that plans and reasons is increasingly separated from the low-level skills that execute movement. In this case, the language model acts as the coordinator, deciding when to grasp an item or navigate to a new position, while the modular skills handle the mechanics of each action.
Such an approach could simplify how robots are deployed in new environments. If a language model can direct a fixed set of reusable skills, a robot might need less retraining or reprogramming when it moves from one kitchen to another, or from a kitchen to a different room altogether. The Stanford and Caltech experiment offers an early indication that this model-first method can work in a realistic domestic task.
The researchers did not present the robot as a finished consumer product, and the demonstration remains an academic proof of concept. Questions about reliability, safety, and how the system handles unexpected obstacles or fragile objects would need further study before such robots could be trusted in everyday homes. The experiment also raises practical considerations about how much of the robot's behavior is determined by the language model versus the modular skills it calls.
Even so, the kitchen trial adds to a growing body of work exploring how large language models can be connected to physical machines. By removing the specially trained control layer, the team has tested a more direct link between AI reasoning and robotic action, with the kitchen serving as a test of whether that link holds up in an unfamiliar, cluttered, real-world setting.
2